| A. Hardware |
|---|
| Size class | Full-size | Full-size | Full-size |
|---|
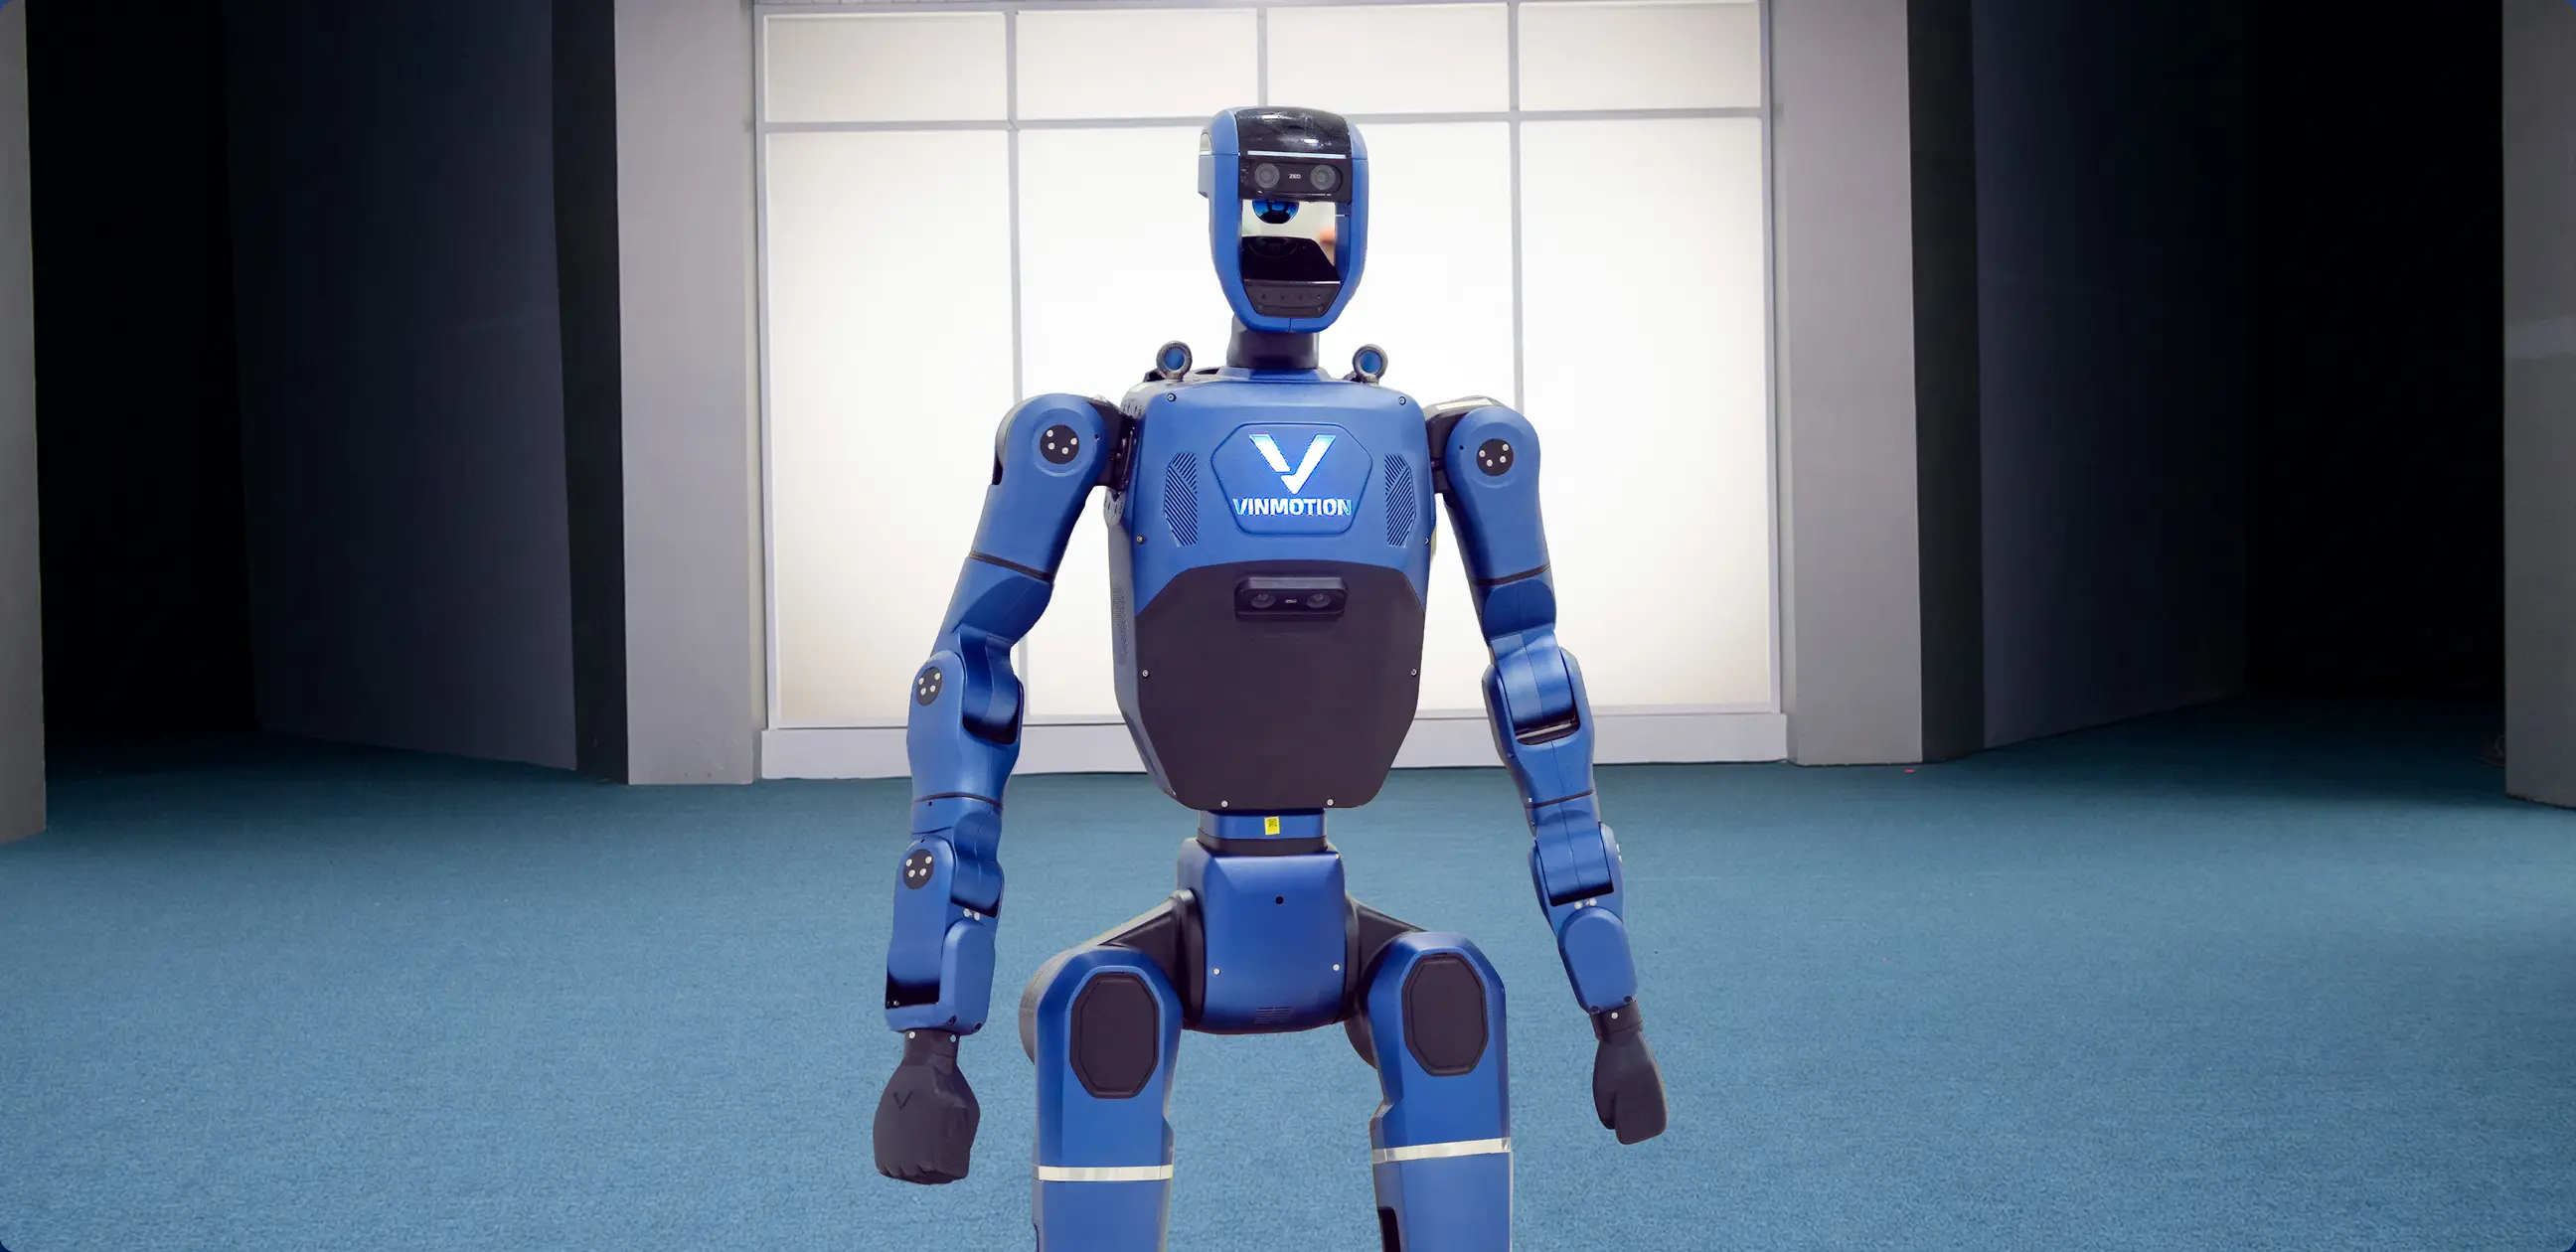
| Dimensions / weight | 1,613 × 450 × 230 mm (standing)
Folded: 840 × 460 × 470 mm
~60 kg (incl. battery) | 1,613 × 450 × 230 mm (standing)
Folded: 840 × 460 × 470 mm
~60 kg (incl. battery) | 1,613 × 450 × 230 mm (standing)
Folded: 840 × 460 × 470 mm
~60 kg (incl. battery) |
|---|
| Total degrees of freedom (DOF) | 29 | 29 | 29 |
|---|
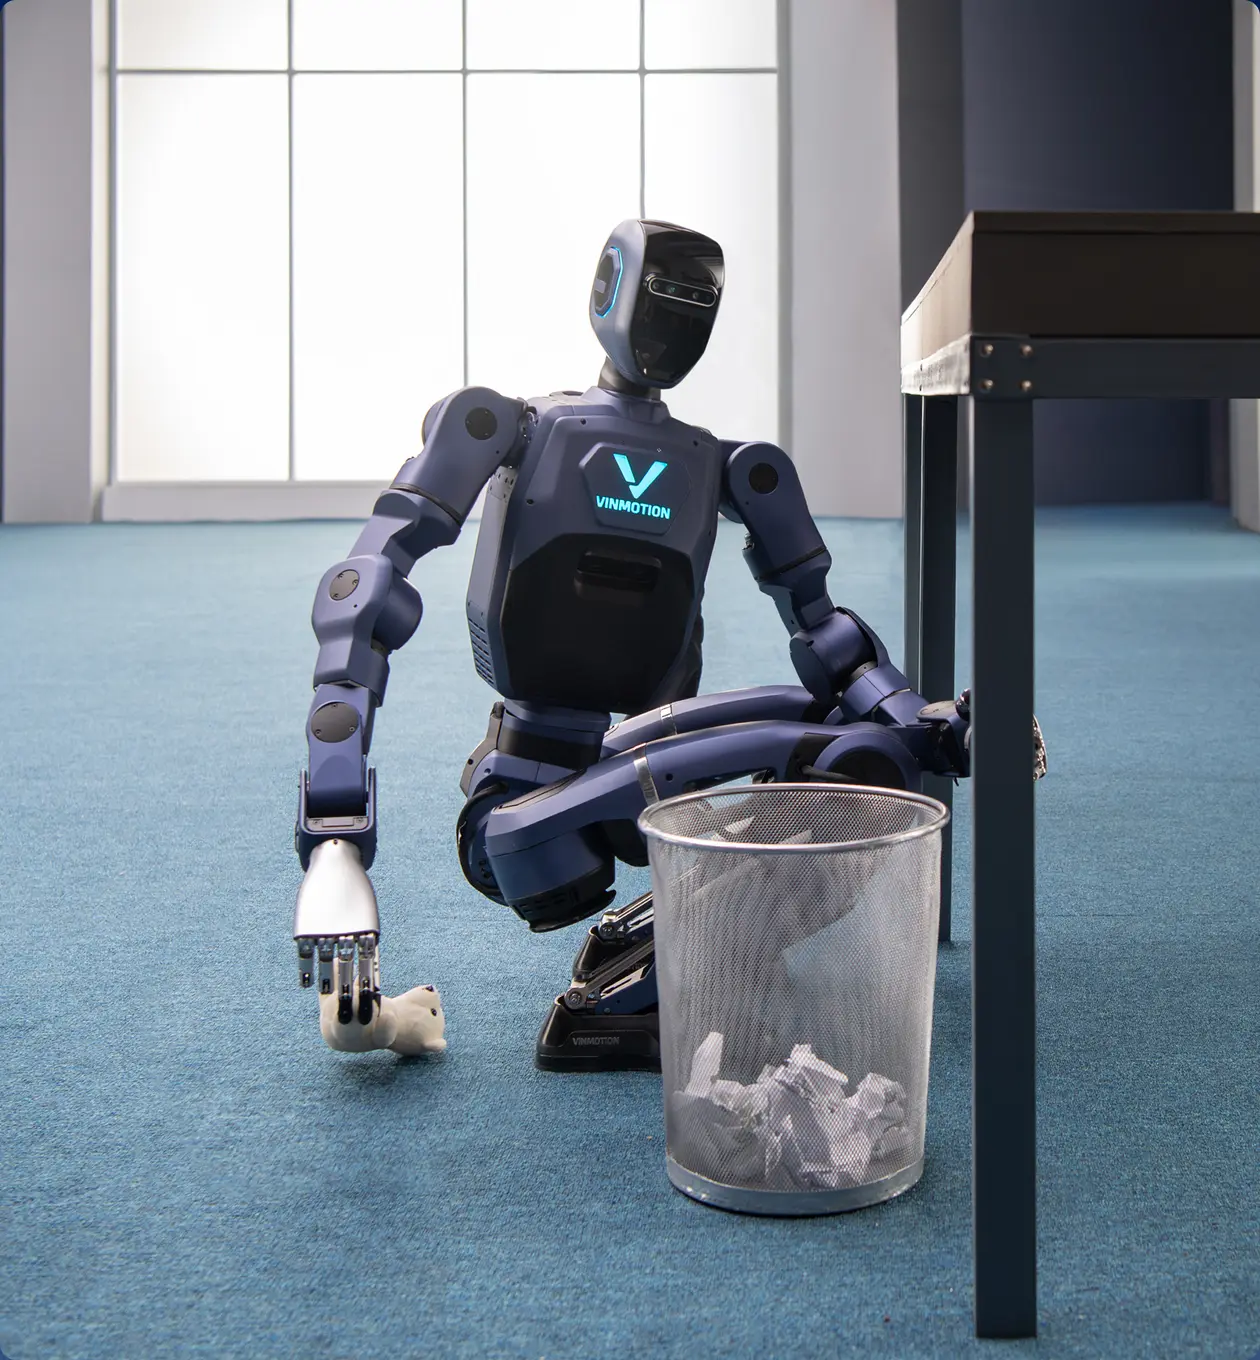
| Hands / manipulation | Rubber hand | Rubber hand | Rubber hand
+ optional hand types available |
|---|
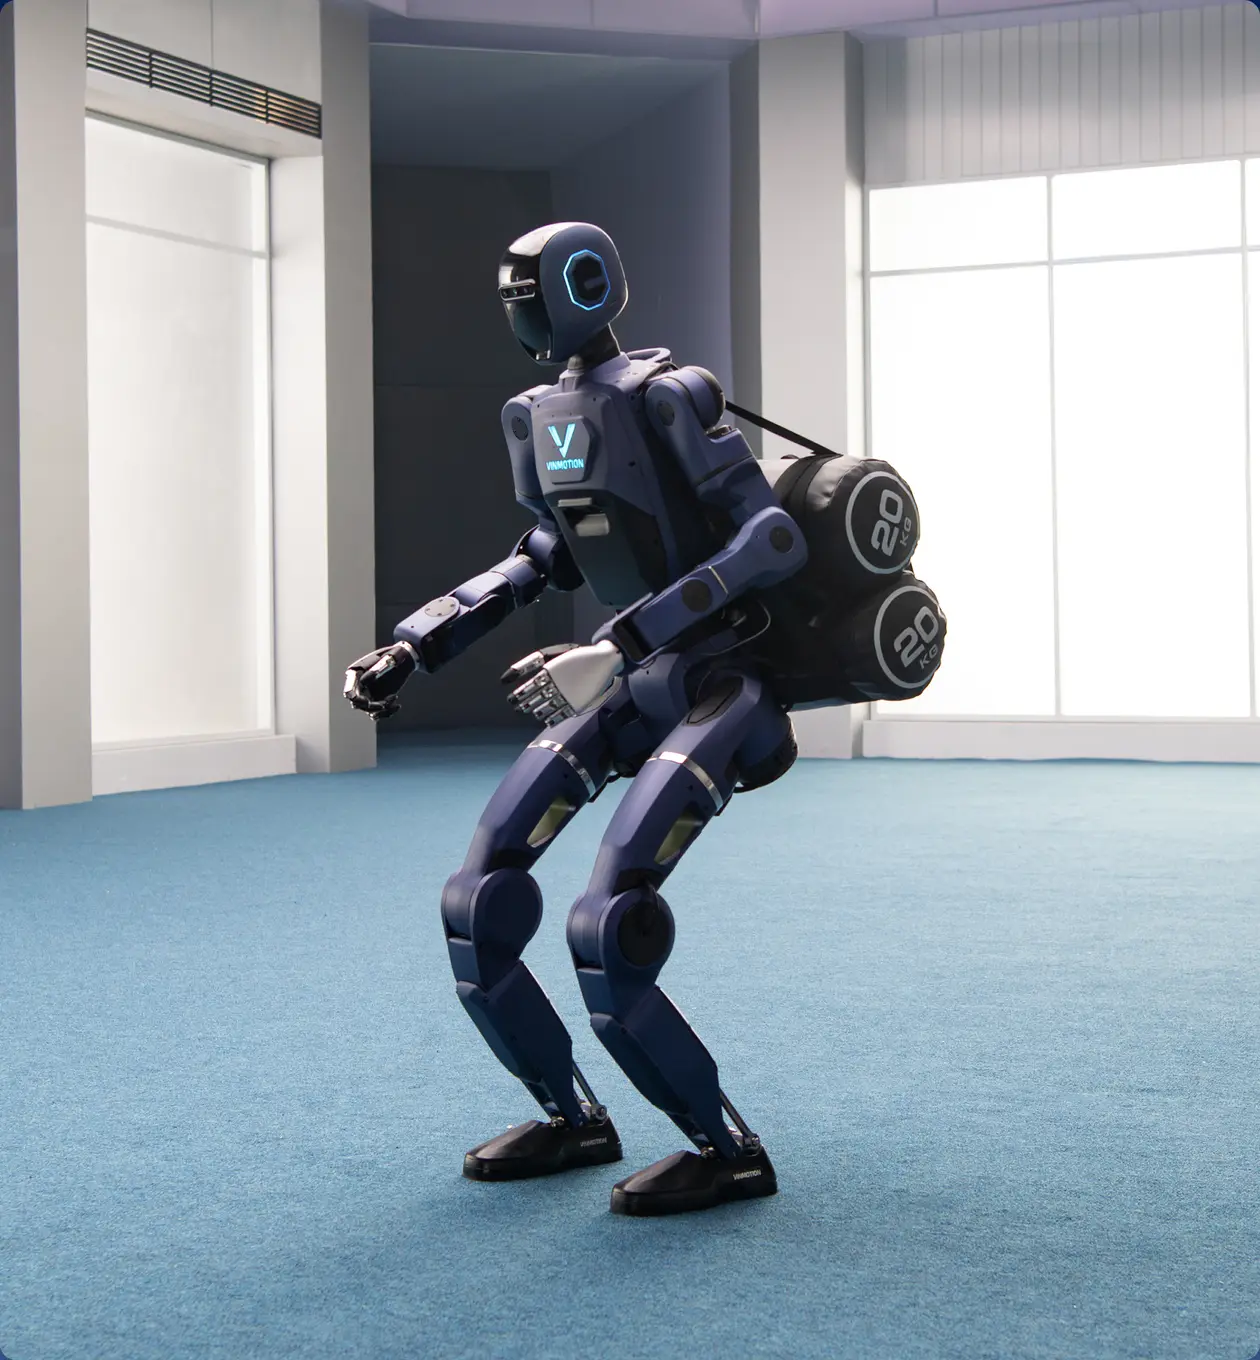
| Payload | 3 kg one-hand / 6 kg two-hand, ≤ 10 min1 | 3 kg one-hand / 6 kg two-hand, ≤ 10 min1 | 3 kg one-hand / 6 kg two-hand, ≤ 10 min1 |
|---|
| Knee torque / speed | 330 N·m peak; 7.2 km/h | 330 N·m peak; 7.2 km/h | 330 N·m peak; 7.2 km/h |
|---|
| Joint range of motion | Waist: ±165°
Knee: −5° to 162° | Waist: ±165°
Knee: −5° to 162° | Waist: ±165°
Knee: −5° to 162° |
|---|
| Base compute | 16-core CPU | 16-core CPU | 16-core CPU |
|---|
| AI module | NVIDIA Jetson AGX Orin | NVIDIA Jetson AGX Orin | NVIDIA Jetson T4000 (Thor series) |
|---|
| Sensors | 3 depth cameras ZEDX Mini
IMU, Sensor
Standard LiDAR (2D) | 3 depth cameras ZEDX Mini
IMU, Sensor
Standard LiDAR (2D)
LiDAR Livox Mid-360 (3D) | 3 depth cameras ZEDX Mini
IMU, Sensor
Standard LiDAR (2D)
LiDAR Livox Mid-360 (3D) |
|---|
| Microphones / Speakers | 2 Microphones (1 Omnidirectional + 1 Directional)
2 × 15 W Speakers (rated) | 2 Microphones (1 Omnidirectional + 1 Directional)
2 × 15 W Speakers (rated) | 2 Microphones (1 Omnidirectional + 1 Directional)
2 × 15 W Speakers (rated) |
|---|
| Connectivity | Wi-Fi 6, Bluetooth 5.2 | Wi-Fi 6, Bluetooth 5.2 | Adds 5G |
|---|
| Operating voltage | 48 V (Li-ion) | 48 V (Li-ion) | 48 V (Li-ion) |
|---|
| Battery / runtime | Smart battery, hot-swappable: 9.6 Ah × 2 packs
~2 h walking / 3 h standing2
1.5 h charging per battery pack | Smart battery, hot-swappable: 9.6 Ah × 2 packs
~2 h walking / 3 h standing2
1.5 h charging per battery pack | Smart battery, hot-swappable: 9.6 Ah × 2 packs
~2 h walking / 3 h standing2
1.5 h charging per battery pack |
|---|
| Charger | 10 A; 100–240 VAC input | 10 A; 100–240 VAC input | 10 A; 100–240 VAC input |
|---|
| Hardware warranty | 12 months | 12 months | 12 months |
|---|
| B. Software & SDK |
|---|
| Basic locomotion control(walk, stand, turn, obstacle avoidance) | Yes | Yes | Yes |
|---|
| Open SDK / secondary development(ROS2, Python, C++) | Limited – basic locomotion and a set of predefined actions | Full ROS2 / Python / C++ access
Open access to motor control | Full ROS2 / Python / C++ access
Open access to motor control
+ Hand / tactile control API
+ On-device AI model execution (Thor) |
|---|
| OTA updates | Maintenance OTA: bug fixes, stability / safety | Feature OTA: new features added per the VMO product roadmap | Feature OTA: new features added per the VMO product roadmap |
|---|
| AI recognition & interaction(face, voice, multilingual conversation) | No | Guest / face recognition
Multilingual conversation | On-device AI processing on Thor – low latency
Works on weak networks |
|---|
| Custom behavior programming / workflows | No | Check-in
Route-based patrol
Reception scenarios | Check-in
Route-based patrol
Reception scenarios |
|---|
| Multi-robot fleet management | No | Monitoring / coordination of multiple robots | Monitoring / coordination of multiple robots |
|---|
| Operational data collection / analytics | No | Operational data dashboard / API (uptime, interaction count, performance) | Operational data dashboard / API (uptime, interaction count, performance) |
|---|
| Appearance / brand customization(voice, outfit, interface) | Paid add-on | Paid add-on | Paid add-on |
|---|
| Technical support & developer documentation | Standard support (basic operation) | Priority technical support queue | Priority technical support queue |
|---|